Perceive
Ground and aerial sensors observe the environment, robot positions and obstacles.
Experimental robotics · Luxembourg
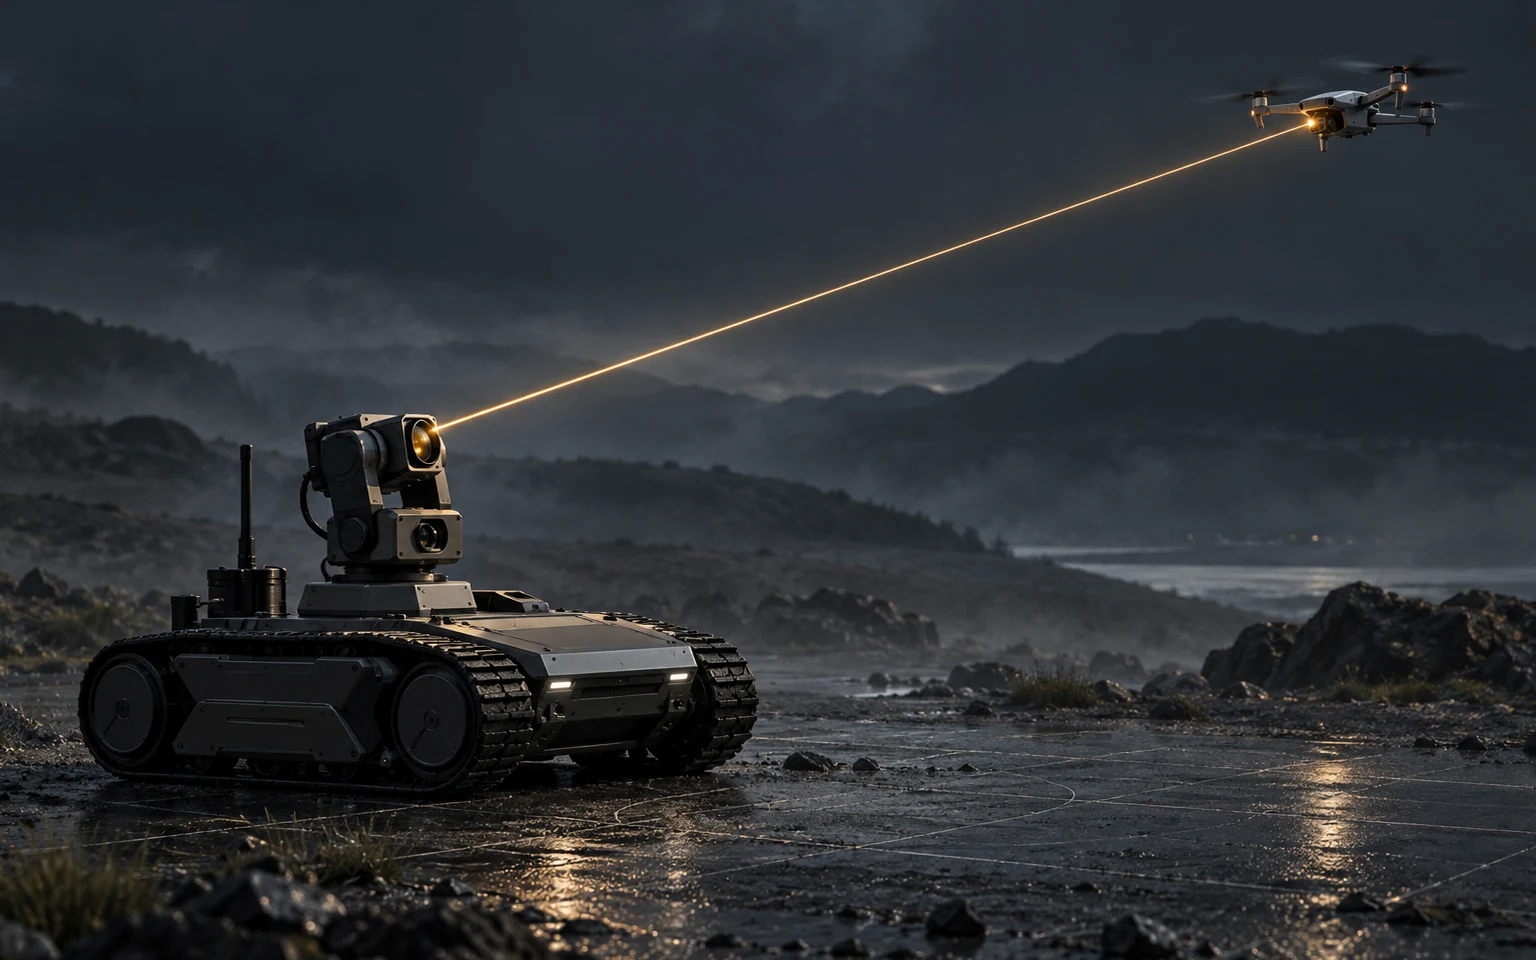
AUROS explores how a ground robot and an aerial drone can coordinate to transfer energy by laser while moving through complex environments.
 AIR NODE / UAVGROUND NODE / UGV
Small electric drones are constrained by battery capacity. AUROS investigates a different approach: transferring energy from a mobile ground robot to a drone while both platforms coordinate their movement and maintain a clear line of sight.
One system. Two robots.
A continuously changing environment.
Research targets
To be assessed through experimental validation.
Targets—not demonstrated performance claims.
AUROS combines laser power transfer with robotic perception, mapping, planning and control. The objective is to keep the beam path viable while both platforms move safely through their environment.
Ground and aerial sensors observe the environment, robot positions and obstacles.
A shared 3D situational model combines geometry with semantic information.
Motion planning calculates complementary paths for the ground robot and drone.
A steerable ground station directs laser energy to a converter on the drone.
Research architecture · Components and behaviour subject to validation.
A steerable laser station, receiver integration and supporting power systems connect the ground and airborne platforms.
The University of Luxembourg’s simultaneous localisation and mapping research supports robot positioning and a changing 3D model of the environment.
Developed at the University of Luxembourg, S-Graphs add meaning and relationships to geometric maps, representing spaces, objects and moving obstacles.
The university’s trajectory optimisation research aims to balance obstacle avoidance, mission coverage and a clear power-transfer line of sight.

Laser power transfer, systems engineering and integration.

The Automation and Robotics Research Group contributes expertise in perception, situational awareness, motion planning and control.


05 / Research status
AUROS is an experimental proof-of-concept research project. Its power, range and endurance figures are targets that will be assessed through system integration and experimental validation.
06 / Get in touch
If you would like to discuss AUROS, a research collaboration or a potential application, contact the SkyGrids team.
Contact SkyGrids